PDF
Laboratory report
PDF · 2.2 MB
Connecting image coordinates, sensors, and physical motion.
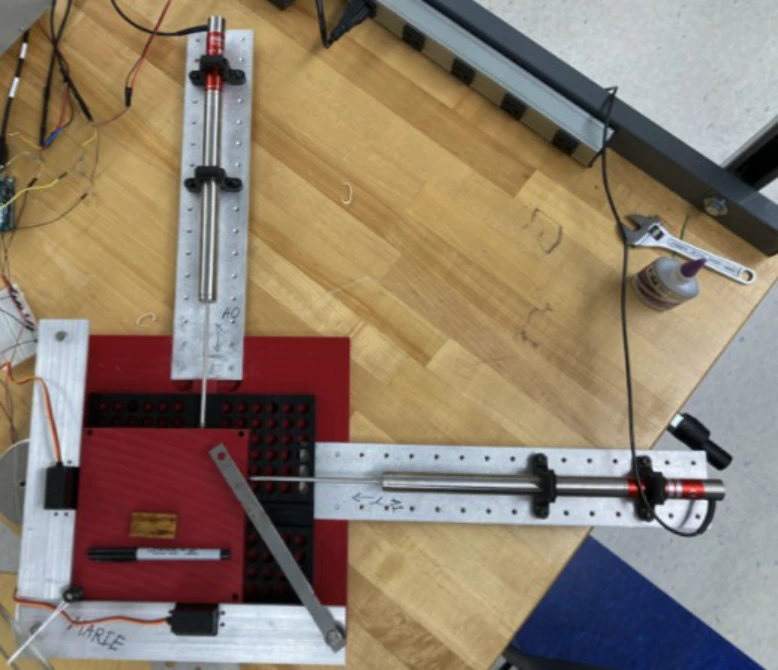
Translation-stage apparatus with servo motors and displacement sensing.
A laboratory project using a two-axis translation stage to turn a digital path into physical motion. MATLAB and an Arduino Uno command servo motors, while calibrated LVDT sensors measure displacement.
This was a collaborative ME 240 lab. The work presented here includes the team’s apparatus, calibration, coordinate-conversion workflow, and reported results.
The report documents a traced Rochester R and the calibration and mapping used to produce it. The result demonstrates the workflow; it does not establish a quantified positioning accuracy or a closed-loop controller.
The lab connected programming with physical measurement. Calibration, coordinate scaling, and mechanical limitations all affected how a digital image became a physical path.